Space robotics animation

Space Robotics & Generative Estimation Lab

Autonomous robotic systems for space exploration, from orbital servicing and cislunar operations to planetary rovers that navigate extreme terrains on the Moon and Mars.

Our Research Meet Our Team

Research Areas

From spacecraft in orbit to rovers on planetary surfaces, we develop the autonomy that enables robots to operate where humans cannot.

Our Lab

The Space Robotics and Generative Estimation (SRGE) Lab, directed by Dr. Cagri Kilic, advances autonomous systems for orbital and planetary robotics. Our research spans two interconnected domains: Orbital Robotics, which includes spacecraft-manipulator control, cislunar trajectory design, satellite station-keeping, CubeSat resilience, and space situational awareness; and Planetary/Terrestrial Robotics, which focuses on cooperative localization, terrain-relative navigation, and multi-robot coordination for lunar and Martian exploration.

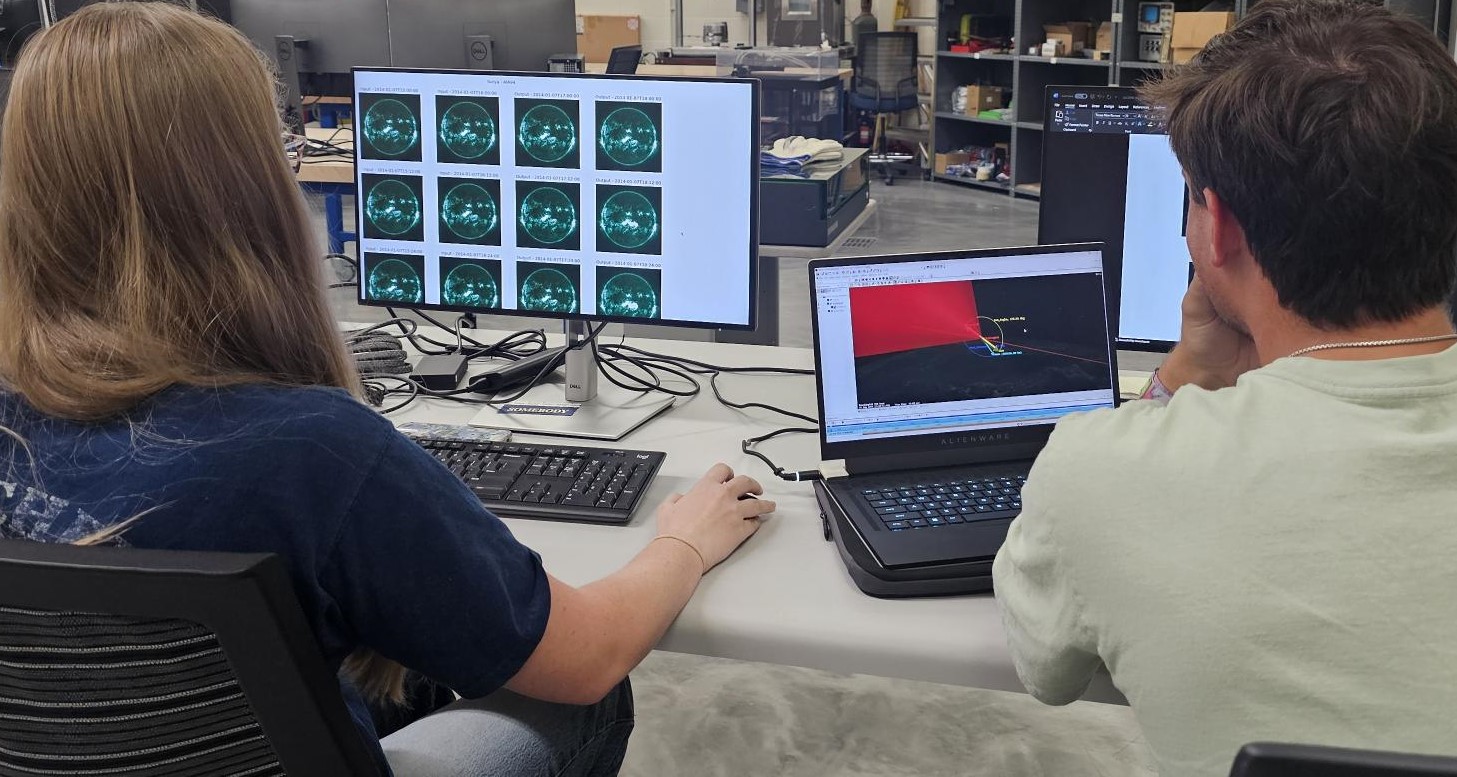
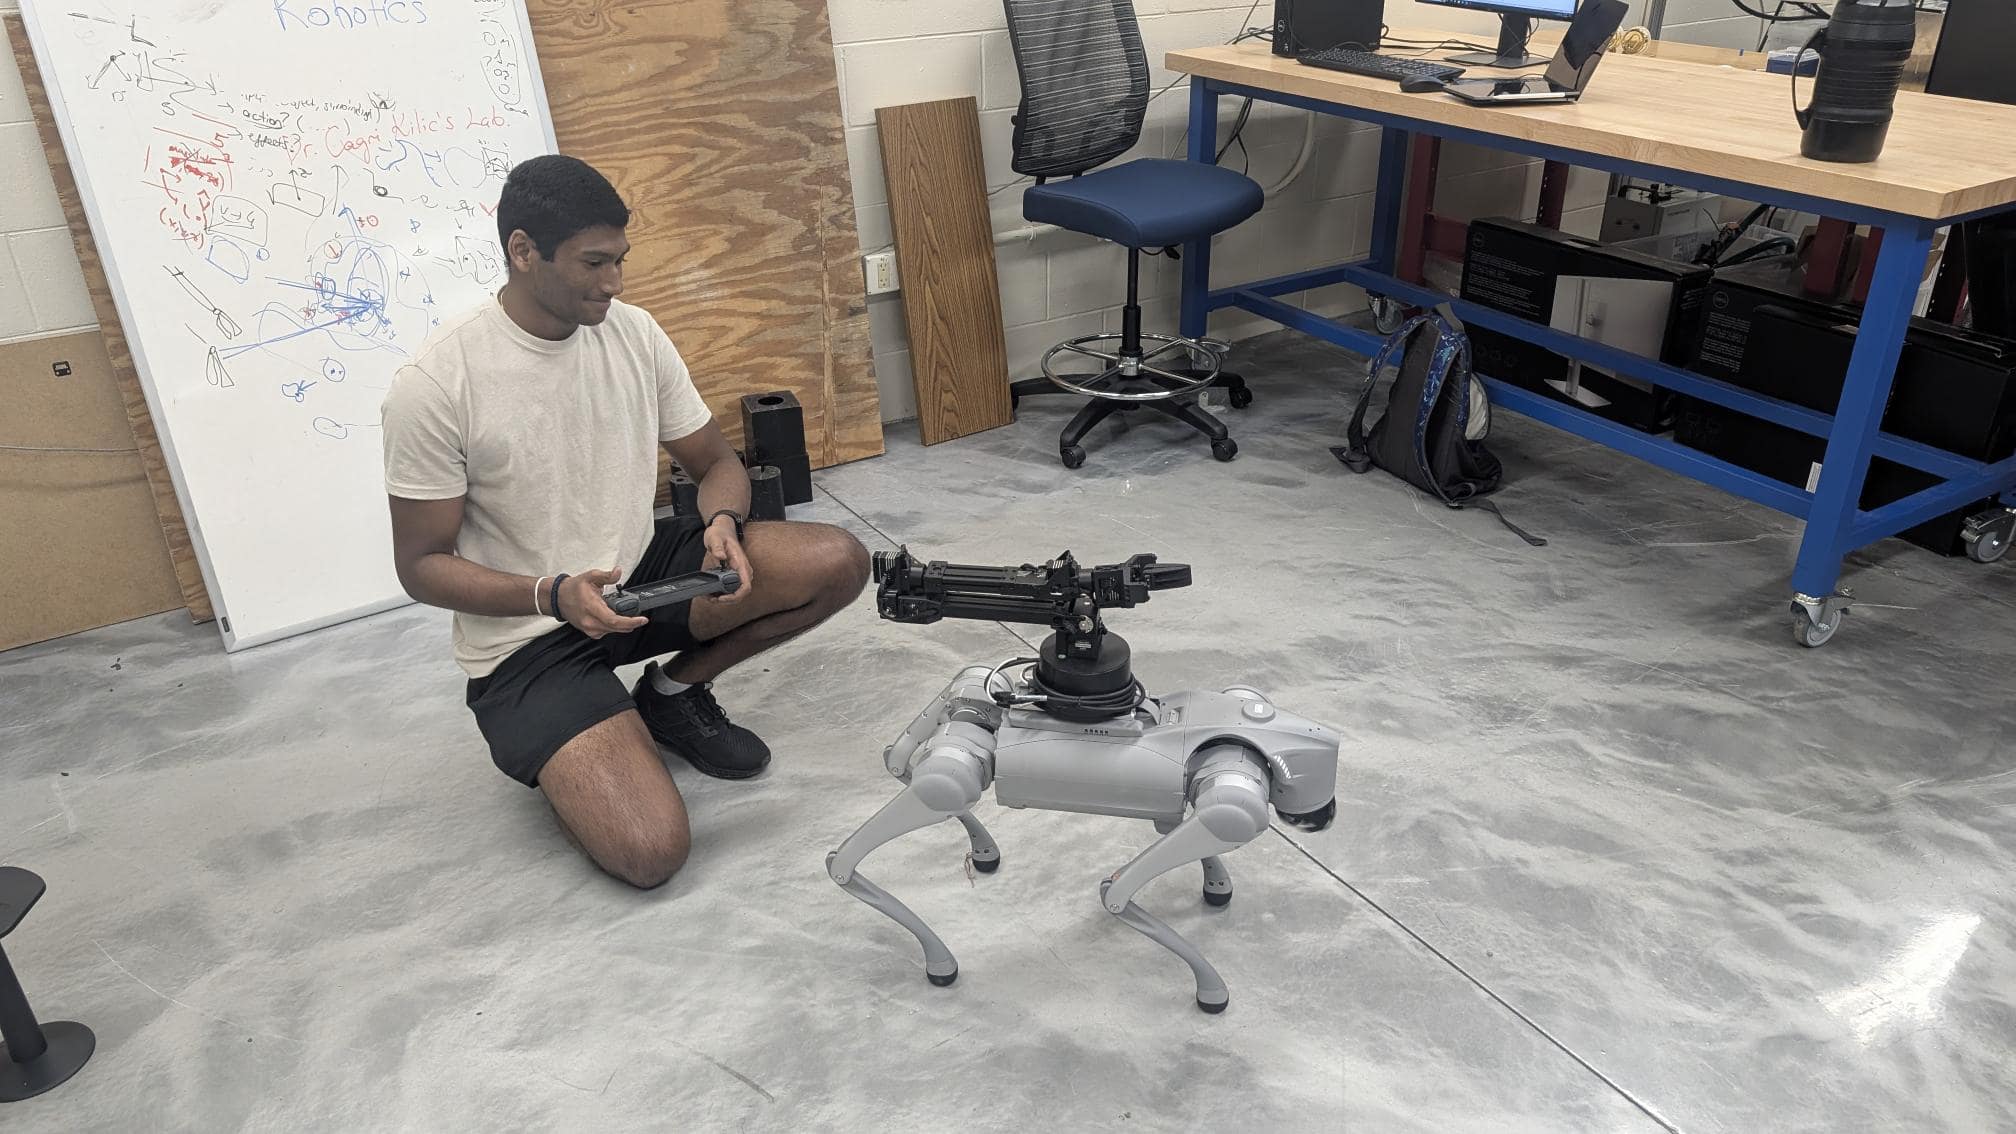
We develop physics-informed state estimation, uncertainty-aware perception with deep learning, and reinforcement learning for robot locomotion and manipulation. Our platforms include quadrupeds, rovers, and hybrid systems validated in unstructured environments. Research integrates multi-sensor fusion for GNSS-denied navigation, terramechanics-based mobility, and bio-inspired design to enable reliable autonomy on the Moon and Mars.

Latest News

Stay informed about our latest developments and achievements.
View All News

Equipment

  • Rover and quadruped robotic platforms
  • Bipedal robot
  • End effector and manipulators
  • High-precision IMUs, LiDAR, and stereo cameras
  • Computational resources for sensor fusion and generative estimation modeling

Contact Us

Interested in our research or potential collaborations? Get in touch with the SRGElab team.

Lab Information

Department of Aerospace Engineering
600 S. Clyde Morris Blvd.
Daytona Beach, FL 32114-3900

Lab Hours

Monday - Friday: 9:00 AM - 5:00 PM
Saturday - Sunday: Closed

For research collaborations, student opportunities, or media inquiries, please contact us directly via email.